Drone Calculator Overview
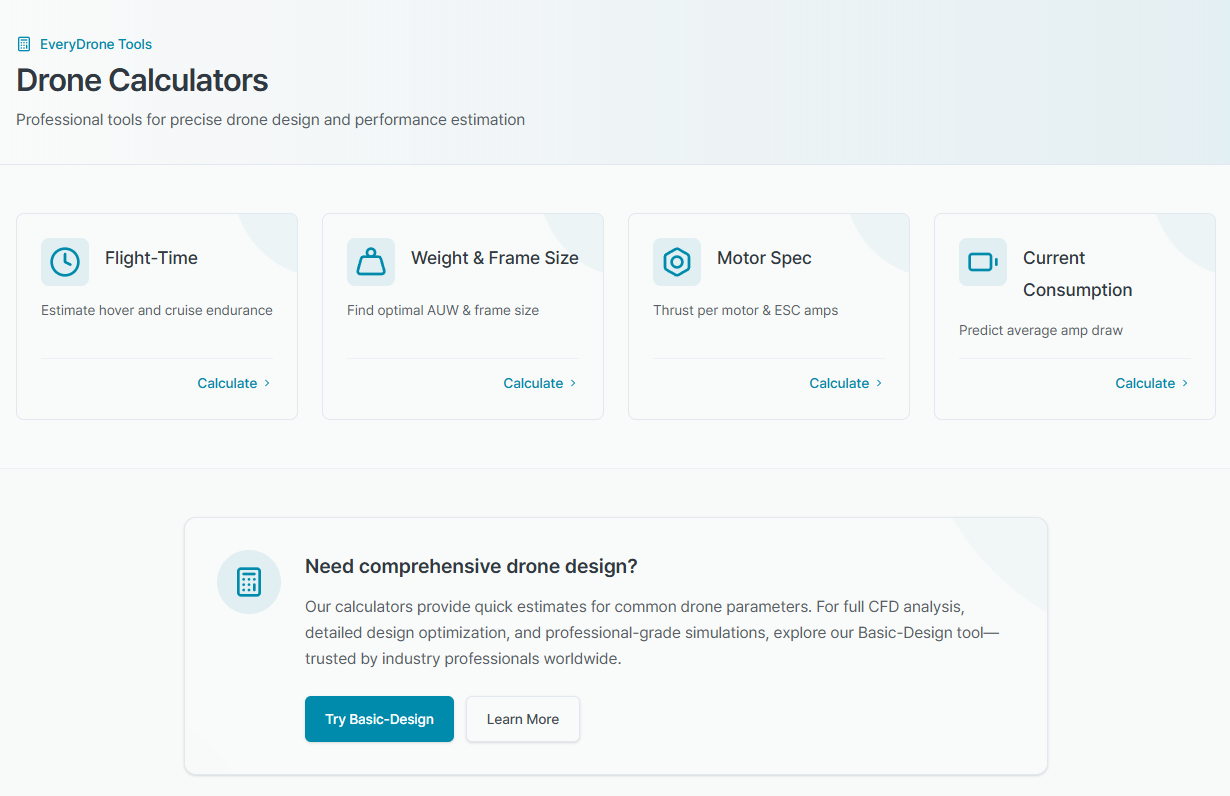
Drone Calculator is a set of tools designed to estimate drone performance based on user input parameters. The tool overview provides direct access to each calculator and a shortcut into Basic Drone Design when a broader design workflow is needed. It offers the following key functions:
- Flight Time: Estimates optimal flight duration based on drone total weight, battery capacity, voltage, and other relevant factors.
- Weight & Frame Size: Calculates the appropriate frame diagonal and disk loading based on drone weight, drone type, propeller diameter, and clearance.
- Motor Spec: Determines the optimal motor specifications based on total weight, thrust-to-weight ratio, and battery cell count.
- Current Consumption: Estimates the required battery capacity and expected flight time based on total weight, number of motors, voltage, and selected flight mode.
Calculator Descriptions
2.1. Flight Time
Hover time is the maximum time a drone can maintain stationary flight, calculated based on battery capacity and power consumption.
Calculates hover time, cruise time, and flight distance, with a battery discharge graph to visually understand the flight profile.
→ View Flight Time Calculator Details
2.2. Weight & Size
Evaluates whether the drone's total weight and frame size are appropriate, and calculates disk loading based on propeller diameter, motor count, and clearance.
→ View Weight & Size Calculator Details
2.3. Motor Spec
Evaluates whether the selected motor is suitable for the drone configuration, and calculates required thrust per motor and ESC current requirements.
→ View Motor Spec Calculator Details
2.4. Current Consumption
Estimates average and peak current based on flight mode, and evaluates the suitability of battery and ESC.
→ View Current Consumption Calculator Details
Quick Start
Each calculator includes a Quick Theory section to help you understand the calculation principles. Please refer to this section before using the calculator.
Need Assistance or Have Questions?
Frequently Asked Questions: FAQ Link
Support Inquiries: support@everysim.io